 Back to docs
Catapult Scoop
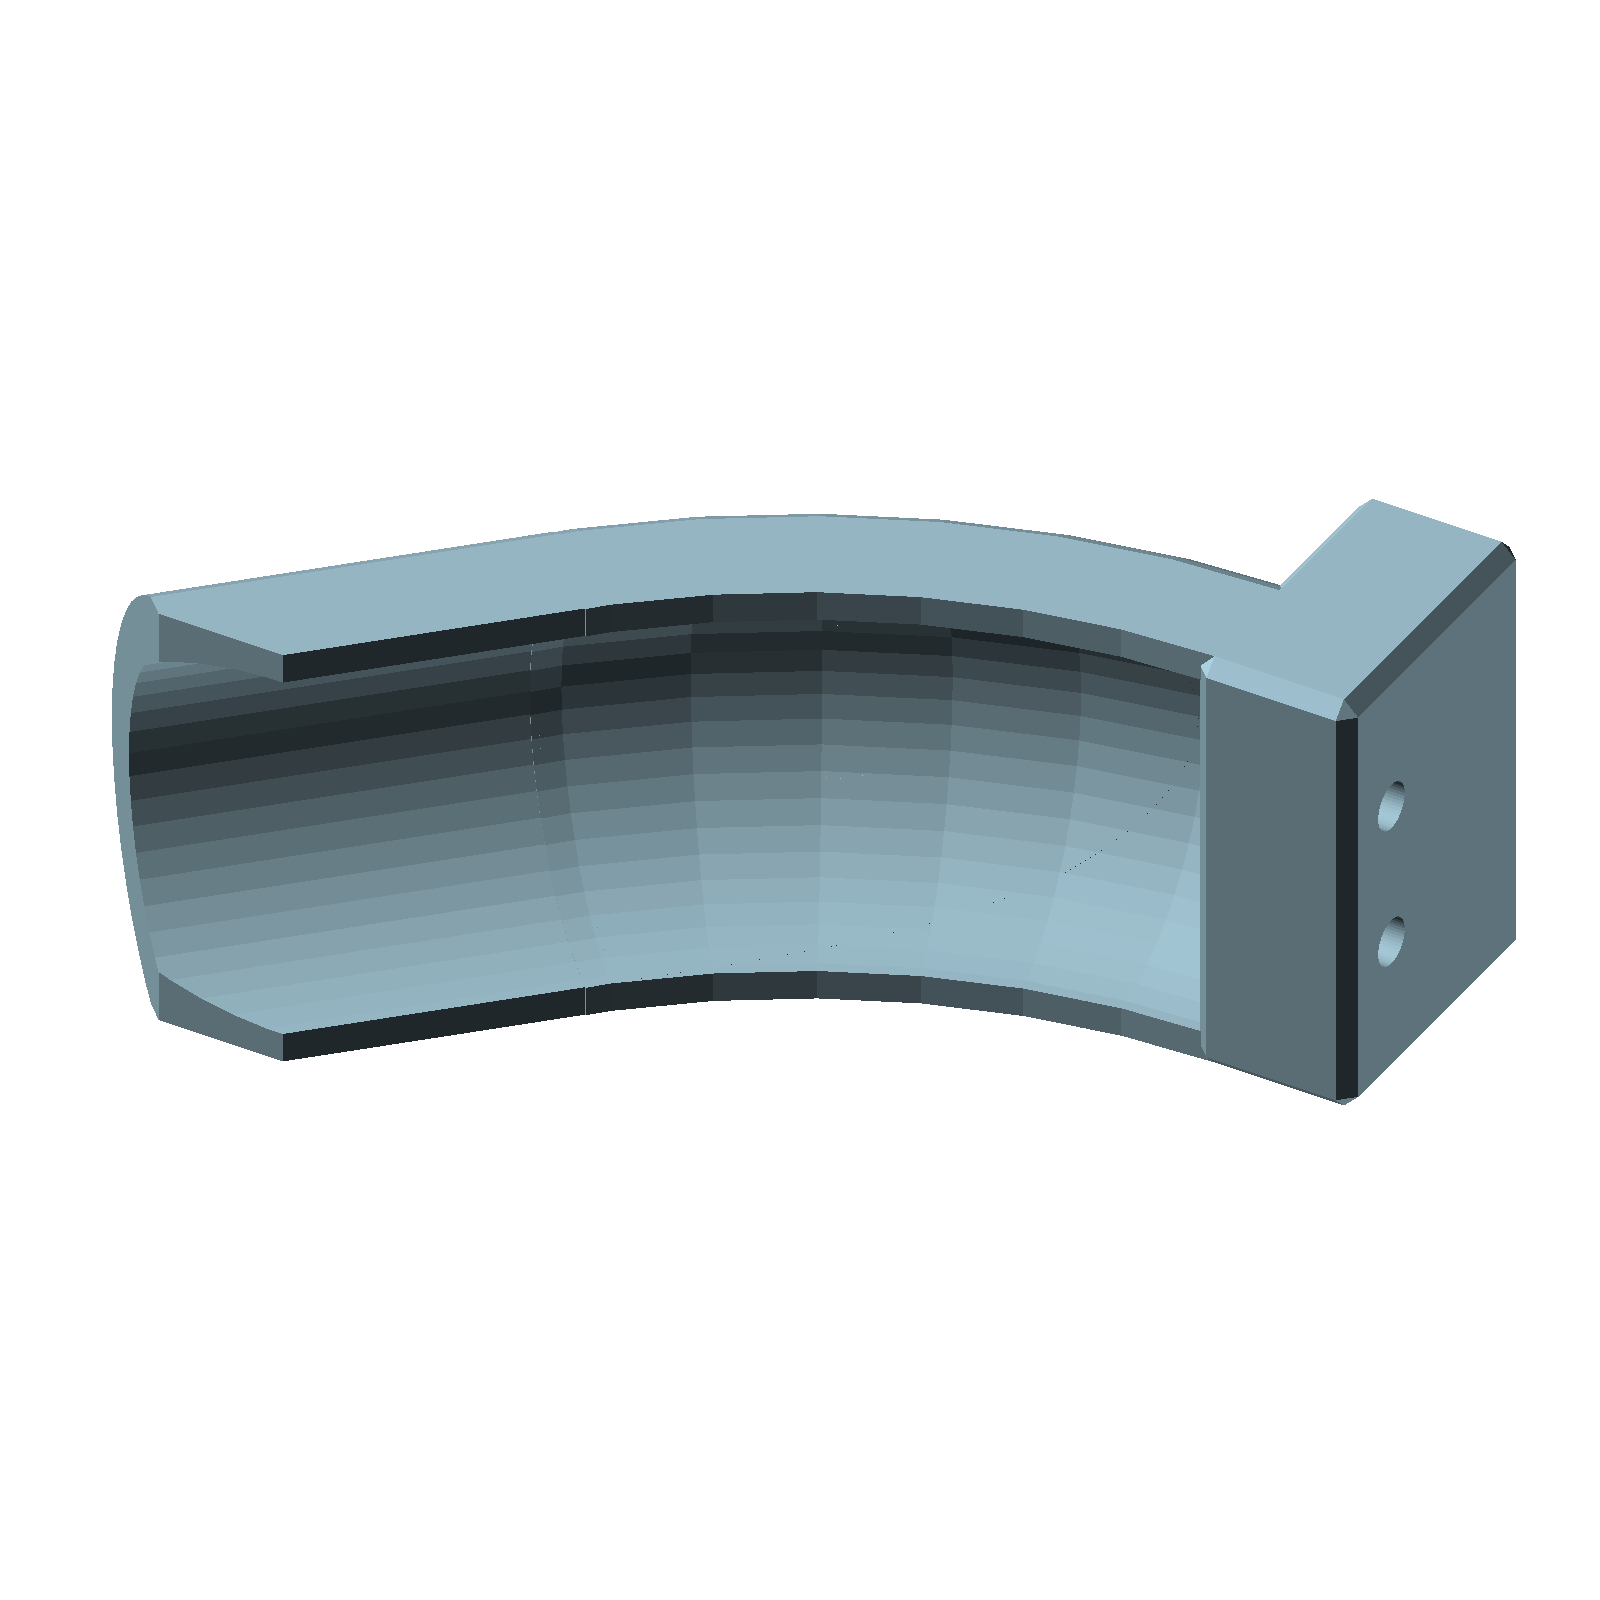
catapult_scoop() is a torus-section scoop with a straight tail and a bolted grid mount.
Customizing catapult_scoop with OpenSCAD parameters
catapult_scoop is a torus-section scoop with a straight tail and an attaching block that bolts to the robot grid:
catapult_scoop(
projectile_diameter = 25,
extra_margin = 1,
straight_section_length = 25,
scoop_extrude_radius = 50,
bolt_hole_diameter = global_default_hole_diameter,
echo_parameters = true
);
| projectile_diameter | diameter of the projectile the scoop throws in mm (default 25). |
| extra_margin | clearance between the projectile and the scoop in mm (default 1). |
| straight_section_length | length of the straight tail in mm (default 25). |
| scoop_extrude_radius | radius the scoop cross section is rotated around in mm (default 50). |
| bolt_hole_diameter | mounting hole diameter in mm (default global_default_hole_diameter, 3.2 mm, sized for m3 screws). |
| echo_parameters | when true (default), the OpenSCAD console echoes the full parameter list when you preview or render the module. |
If you leave a parameter out of the module call, that parameter will just have the default value. For example, these are all valid module calls:
catapult_scoop();
catapult_scoop(projectile_diameter=20);
catapult_scoop(straight_section_length=40, scoop_extrude_radius=60);